State Feedback and Observer · Lesson
English translation
Execution conditions
MATLAB · Control System Toolbox
Topics covered
Estimate velocity to control a system that measures only position, and compare estimated velocity and noise sensitivity.
Two conditions to check before design
Controllability asks whether inputs can move the state; observability asks whether the output's time evolution can distinguish initial states. For a two-state model, compare the ranks of [B, AB] and [C; CA] with the state count 2.
Control using unmeasured states
For state feedback , use estimated states when velocity cannot be measured directly. The observer updates its model prediction by adding a measurement-error correction.
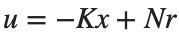
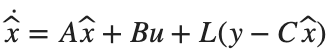
In an ideal linear model, controller and estimator poles can be designed separately. However, with an excessively fast observer, examine how measurement noise propagates to the control input.
Checking the same design in MATLAB
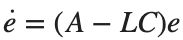
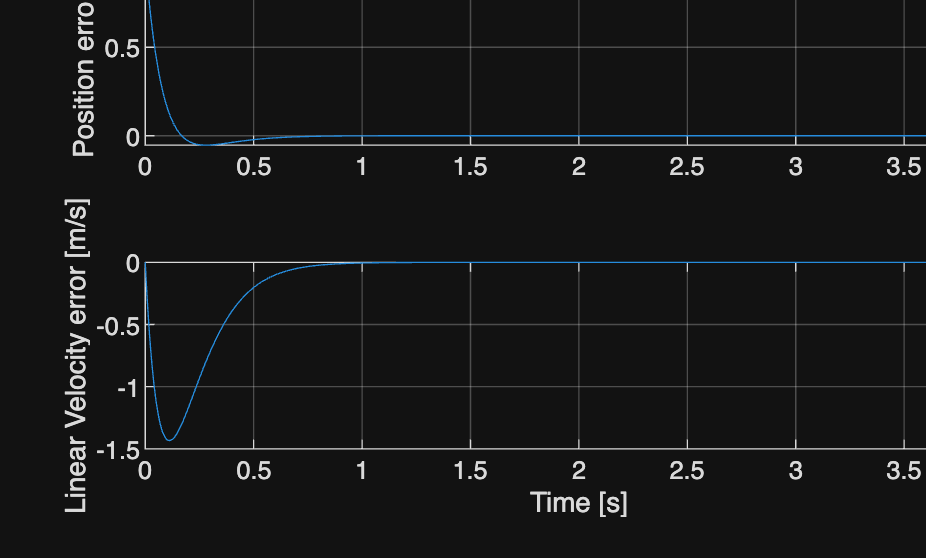
The observer's state-estimation error is governed by , independently of the input. Place the controller and observer poles separately, then compare actual and estimated states over time.
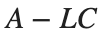
Controller and estimator for the same model
Calculate both pole placements and examine estimation-error convergence independently of the input.
%% Worked example
A=[0 1;-2 -3]; B=[0;1]; C=[1 0];
K=place(A,B,[-2 -4]); L=place(A',C',[-8 -10])';
disp(K); disp(L); assert(norm(K-[6 3])<1e-10 && norm(L-[15;33])<1e-10);
t=linspace(0,4,801)'; estimationError=initial(ss(A-L*C,zeros(2,1),eye(2),zeros(2,1)),[1;0],t);
figure; tiledlayout(2,1);
nexttile; plot(t,estimationError(:,1)); ylabel('Position error [m]'); grid on
nexttile; plot(t,estimationError(:,2)); ylabel('Linear Velocity error [m/s]'); xlabel('Time [s]'); grid on
disp(estimationError(end,:));