
영상 검출에서 안전한 제어 명령으로
clc;
clear variables;
mode = 0; % 0: simulation mode / 1: real mode
텔로 이륙하기
if (mode>0)
my_tello = ryze();
takeoff(my_tello);
pause(3); % wait for stability
else
my_tello = 0;
end
영상 가져오기
if (mode>0)
my_camera = camera(my_tello);
img = snapshot(my_camera);
%imwrite(img, 'snapshot.png');
else
img = imread('snapshot.png');
end
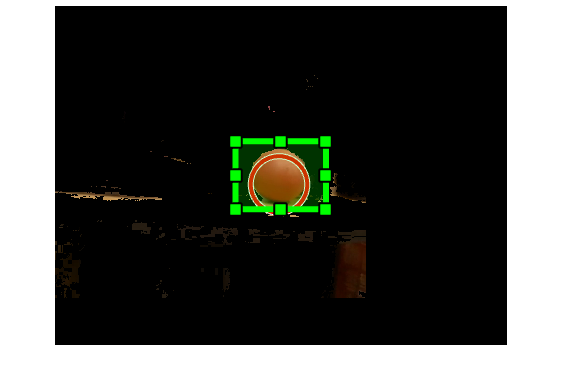
붉은색 공 추적하기 - 공이 화면 중앙에 오도록 제어하기
[height, width, channels] = size(img);
center = [width/2, height/2];
offset = [round(width/10), round(height/10)];
flag = true;
while(flag)
[ball_pos, ball_radius] = FindRedBall(img);
displace = (ball_pos - center);
[img, flag] = MoveAndSnap(mode, my_tello, img, displace, offset);
drawrectangle('Position',[center-offset,offset*2],'Color',[0 1 0]);
a = input('press enter');
end
텔로 착륙하기
if (mode>0)
land(my_tello);
end
clear variables;